Back to market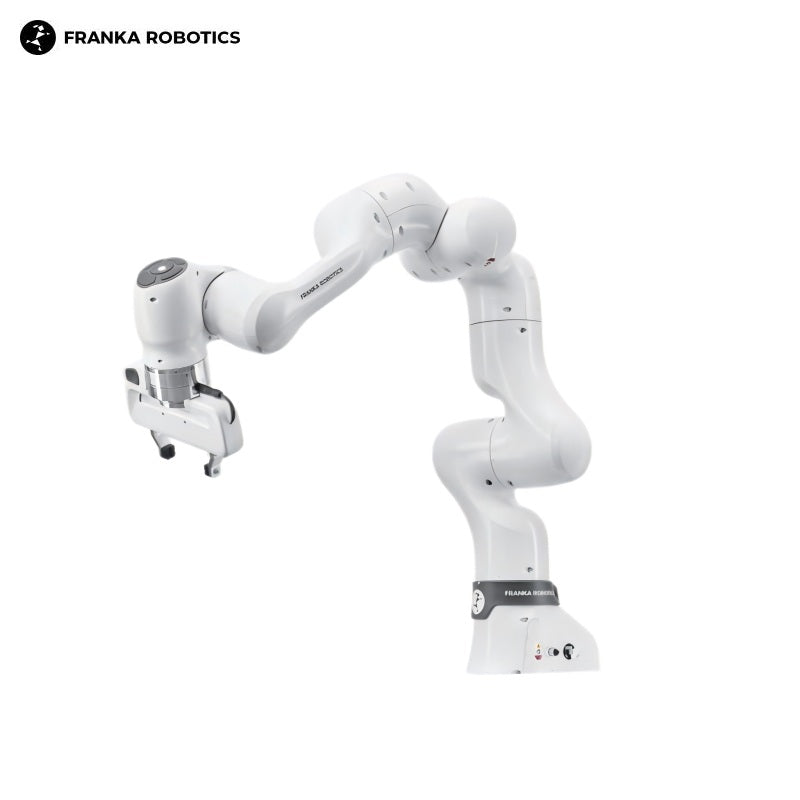
- Degrees of Freedom
- 7.0
- Maximum Reach
- 855.0 mm
- Repeatability
- 0.1 mm
- Payload Capacity
- 3.0 kg
Overview
The Franka Research 3 (FR3) is a 7-degree-of-freedom collaborative/research robot arm with integrated joint torque sensors on all 7 axes, enabling force-sensitive and compliant manipulation. It offers approximately 855 mm maximum reach, 3 kg payload, and better than ±0.1 mm repeatability. The arm is programmed and controlled via the Franka Control Interface (FCI) with the libfranka C++ library and franka_ros, providing 1 kHz real-time access to torque and motion control for research applications.
Highlights
- 7-DoF collaborative research arm with joint torque sensors on all 7 axes
- ~855 mm reach, 3 kg payload, <±0.1 mm repeatability
- Franka Control Interface (FCI) + libfranka for 1 kHz real-time control
- Composed 2x in the Dual Franka FR3 bimanual platform
Specifications
General
- Degrees of Freedom
- 7.0
- Maximum Reach
- 855.0 mm
- Repeatability
- 0.1 mm
- Payload Capacity
- 3.0 kg
- Arm Type
- 7-axis collaborative research arm with joint torque sensing on all axes
- Weight
- 18.0 kg