Back to market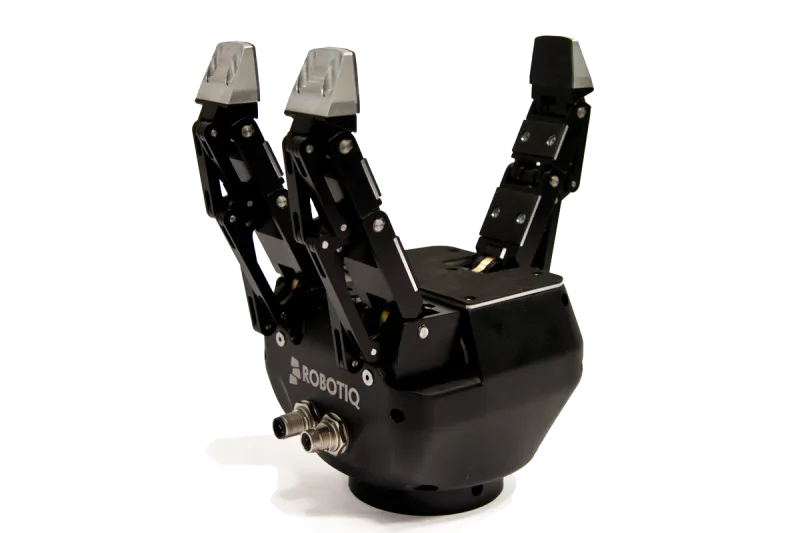
- Number of Fingers
- 3.0
- Max Payload Capacity
- 10.0 kg
- Weight
- 2300.0 g
Overview
The Robotiq 3-Finger Adaptive Robot Gripper is an electric, underactuated multi-finger end-effector designed for versatile, hand-like grasping. It offers multiple grip modes with programmable stroke, force, and speed for industrial pick-and-place and machine tending applications.
Specifications
General
- Number of Fingers
- 3.0
- Max Gripping Force
- 70.0 N
- Max Payload Capacity
- 10.0 kg
- Finger Stroke
- 155.0 mm
- Actuation
- electric
- Product Category
- Multi-Finger/Anthropomorphic Hand; electric adaptive gripper (EOAT)
- Series / Model
- 3-Finger Gripper (3F Gripper); legacy: S-Model / Adaptive Gripper
- Repeat Positioning Accuracy / Repeatability
- 0.05 mm
- Operating Voltage
- 24.0 VDC
- Peak Current
- 1.5 A
- Weight
- 2300.0 g
- Communication interfaces / protocol support (as documented/sold across variants)
- Specific commercial SKUs vary by communication option / kit (e.g., UR kits, industrial network interface options).
- Model variants (right/left; bus-associated in integrator listings)
- Communication/kit variants (e.g., UR kits; industrial network interface options).
- Control mode support (as stated)
- Programmable grip force; programmable stroke; fingers can be controlled independently; 4 grip modes.
- Operating Voltage Range
- 24.0-28.0 VDC
- Grasp Types Supported
- 4.0
- Max Payload Capacity (alternative listing - reseller/aggregator claims)
- Friction grip: 2.5 kg; Form-fit/encompassing: 10 kg
- Grip force (programmable) range
- 30.0-70.0 N
- Stroke (programmable)
- 155.0 mm
- Closing speed (programmable) range
- 22.0-110.0 mm/s
- Payload (form-fit / encompassing)
- 10.0 kg
- Payload (friction grip)
- 2.5 kg
- Repeatability (fingertip grip)
- 0.05 mm
- Grip modes
- 4.0
- Finger control
- Fingers can be controlled independently.
- Mass
- 2.3 kg